RIDE Dataset: Imaging Radar based Multi-Modal Dataset for Autonomous Driving
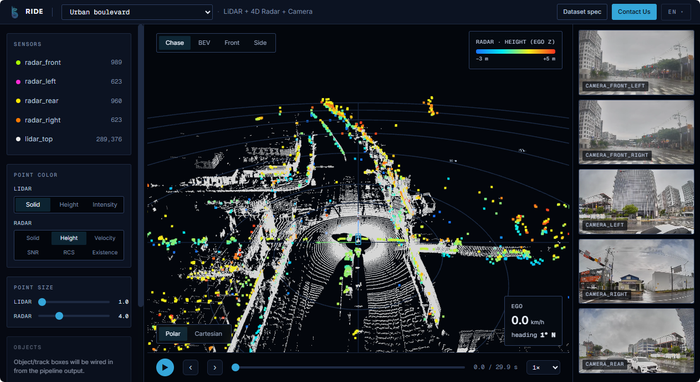
Overview
RIDE is a high-resolution, multi-modal dataset captured from real-road driving by sensor manufacturer bitsensing. Centered around four 360° AFI920 4D Imaging Radars, it bridges the physical perception gap left by camera- and LiDAR-only setups under challenging conditions such as adverse weather, glare, and night driving.
Highlights
• 11-Device Synchronized Sensor Suite:
4× AFI920 4D Imaging Radar (360° FOV, elevation/velocity), 1× Hesai OT128 LiDAR, 5× High-Res Cameras, and Novatel RTK-GNSS/INS.
• Production-Scale Real-World ODD: Over 10,000+ km, 150+ hours, and 5.4M+ synchronized frames across urban, highway, unpaved roads, and harsh weather conditions (rain, fog, low light).
• Standardized & Self-Contained: Structured in high-efficiency Parquet format compatible with ISO/PAS 8800 and ASAM OpenLABEL. Every 60-second clip bundles synchronized streams and metadata with zero external dependencies.
Primary Use Cases
• Radar World Foundation Models: Simulation fidelity enhancement for generative AI and closed-loop rollouts.
• Occupancy & BEV Mapping: HD-map and free-space prediction directly from 4D radar point clouds.
• End-to-End Driving AI: Velocity-aware policy learning and sensor fusion benchmarking.
• Pre-Hardware Sensor Evaluation: Comprehensive algorithmic validation prior to physical sensor hardware integration.